|
ELLIS PhD Student · Robot Learning, Perception & Navigation Hello! I am an ELLIS PhD Student advised by Professor Wolfram Burgard and co-advised by Professor Cordelia Schmid. My research interests span a lot of fields but broadly I work on building robust models for robot perception across multiple modalities - vision, language, sonar, audio etc. and their use in downstream applications such as robot navigation. I graduated from Carnegie Mellon University where I was fortunate to be a part of the Robot Perception Lab. At CMU, I worked on Underwater Perception and Object SLAM. I was also a Robotics Software Engineer at a startup where I worked on the localization stack for a mobile robot system. |
|
|
|
* denotes equal contribution |
|
Workshop · CoRL 2026, The Science of Physical AI Safety Spotlight
- We test how images, instructions, and visual memory causally affect four VLM-based navigation policies. |
|
|
ICRA, 2026
Workshop · IROS 2025, Generative AI for Robotics and Smart Manufacturing Best Poster
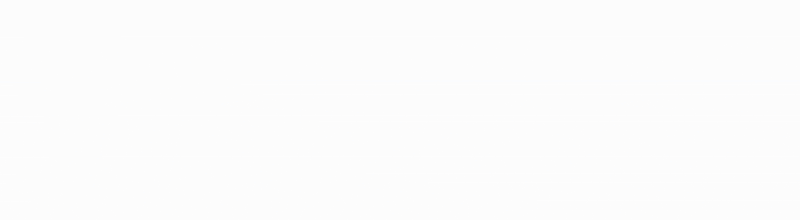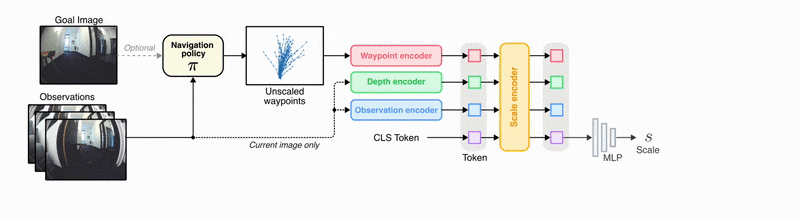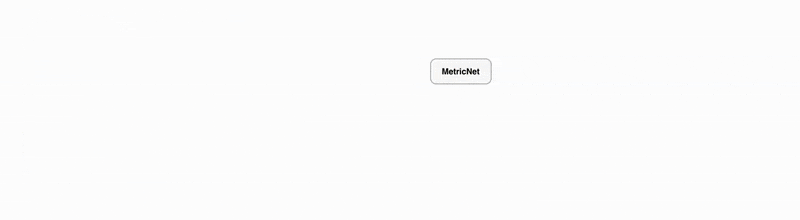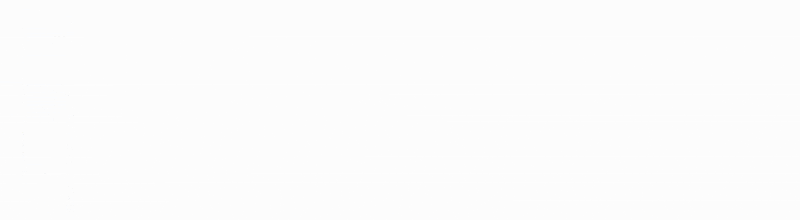
- Designed a network to predict the scaling factor for generative navigation policies to create metric waypoints in the real-world |
|
IROS, 2025
Workshop · CoRL 2024, Learning Effective Abstractions for Planning (LEAP)
Workshop · CoRL 2024, Differentiable Optimization Everywhere: Simulation, Estimation, Learning, and Control
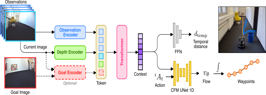
- Used Conditional Flow Matching(CFM) along with depth embeddings for efficient goal-conditioned robot navigation as opposed to diffusion policies |
|
ICRA, 2024
Workshop · IROS 2023, 2nd Advanced Marine Robotics TC
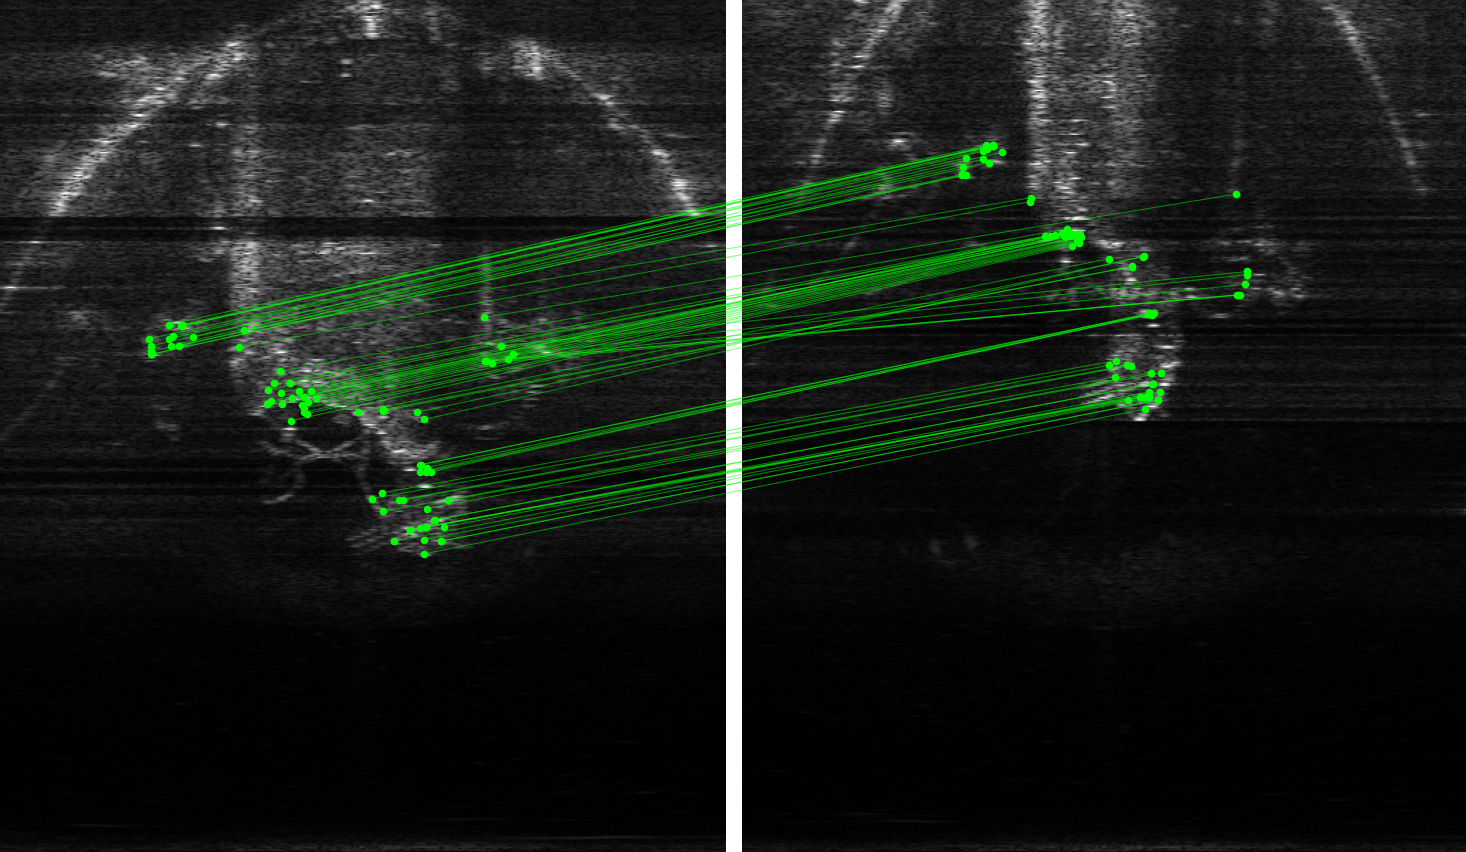
- Solved data association for underwater SLAM through a novel method for sonar image correspondence using Learned Features. |
|
Workshop · ICLR 2025, “Will Synthetic Data Finally Solve the Data Access Problem?”
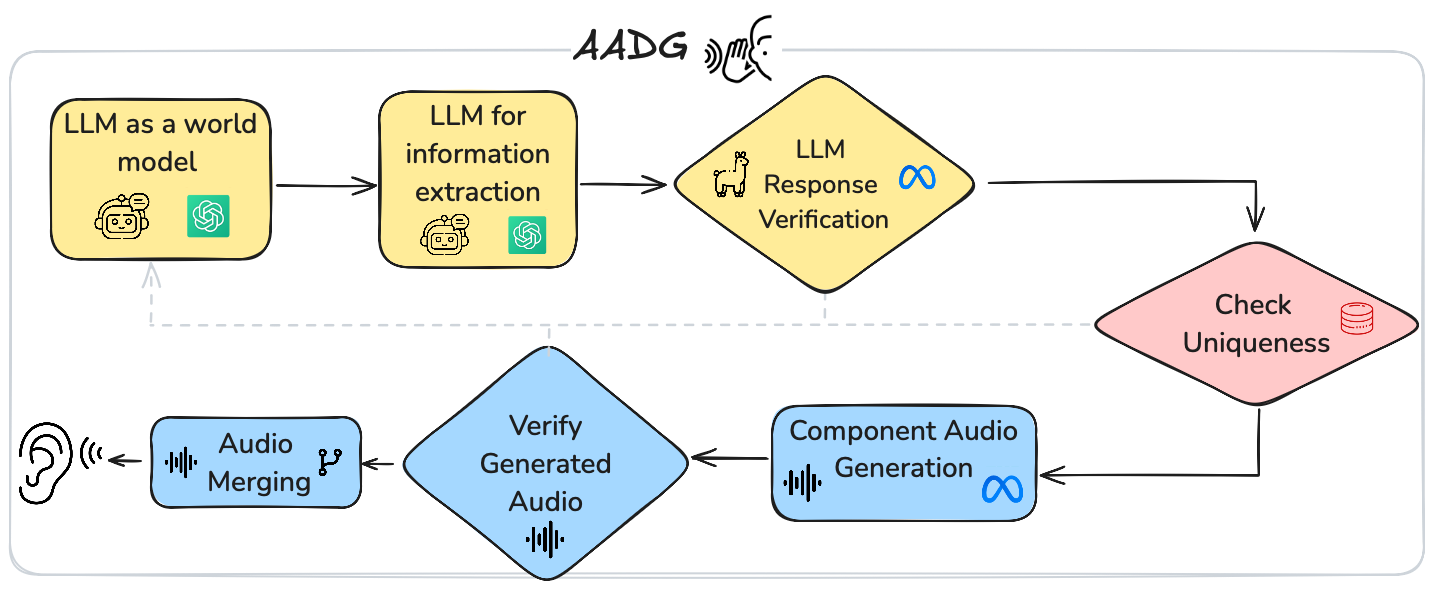
- Developed a novel audio generation framework (AADG) using LLMs and text-to-audio models to simulate realistic scenarios specifically for Audio Anomaly Detection and Localization. |
|
AI Magazine
Workshop · AAAI 2023, Second Workshop on AI for Credible Elections
- Finetuned Longformer on a scraped Wikipedia dataset to find most important tokens based on attention score. |
|
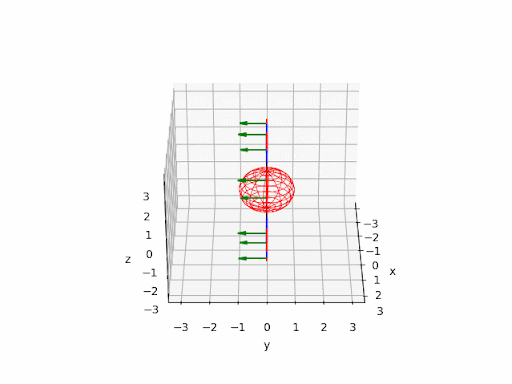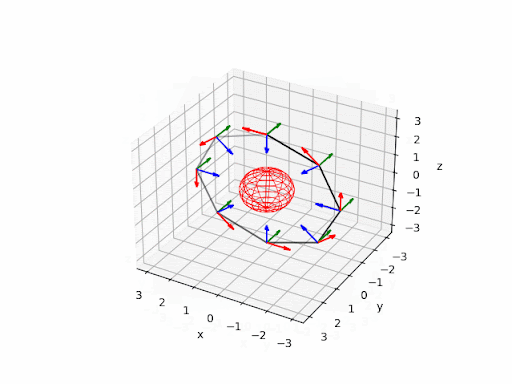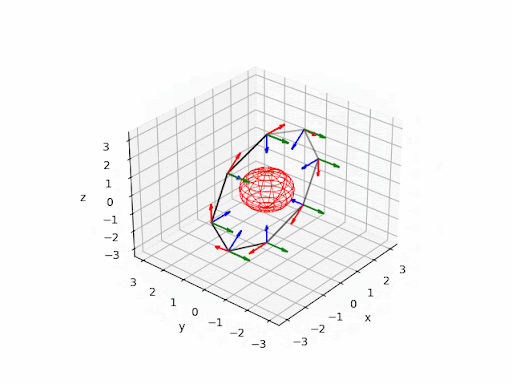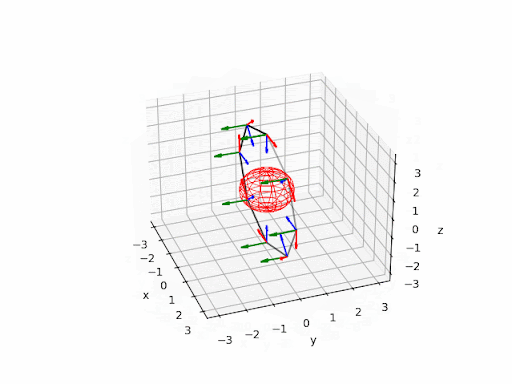
- Implemented on Object based semantic SLAM, created low-memory metric semantic maps for multi-robot communication. |
|
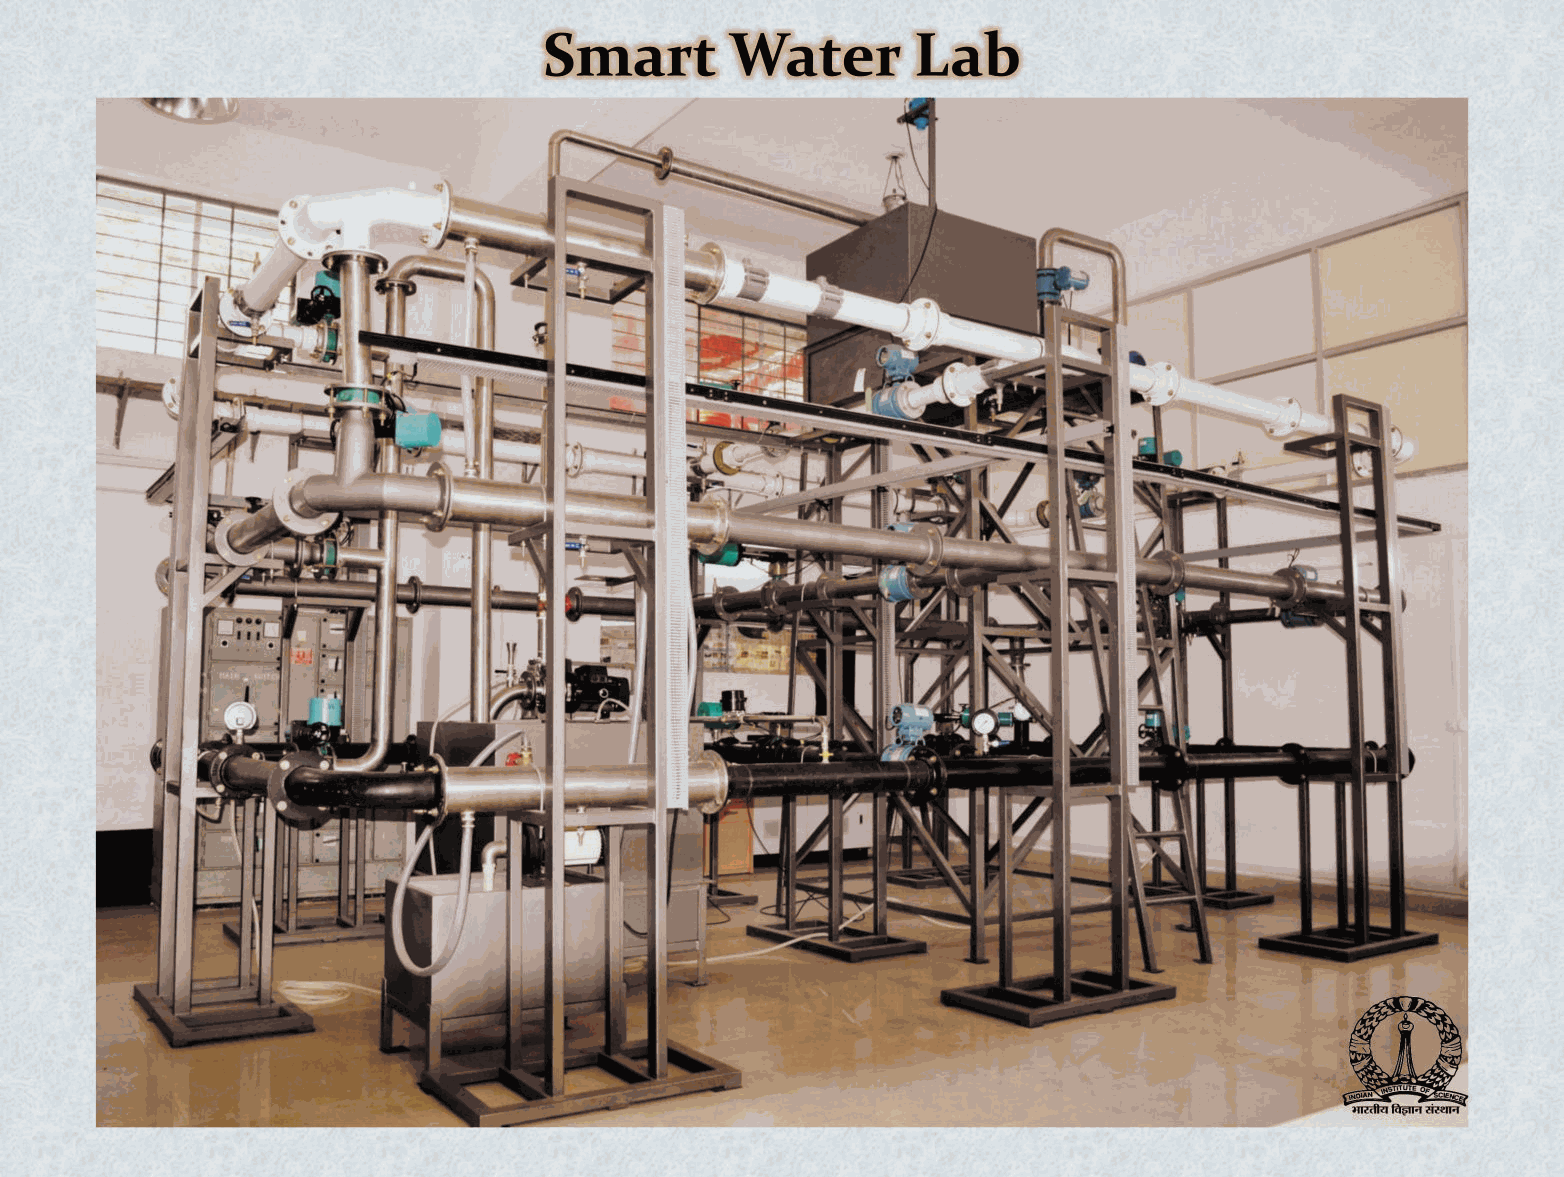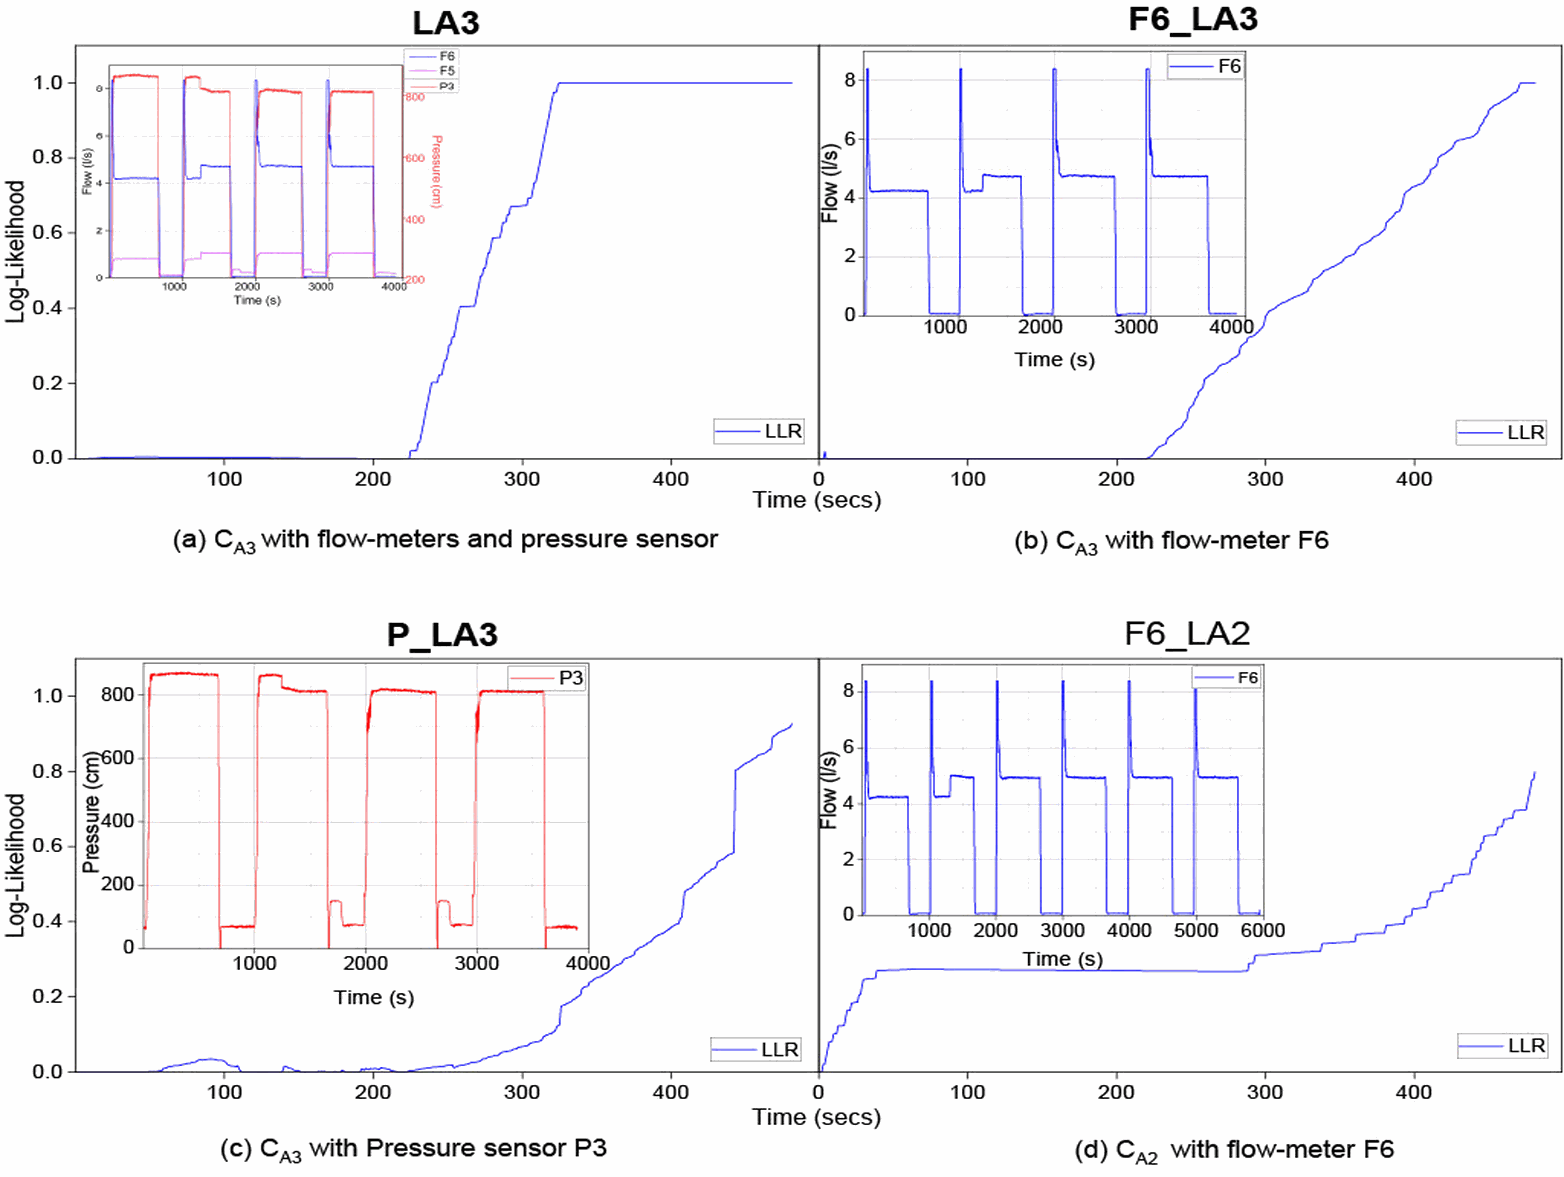
- Developed an algorithm for detecting and localizing multiple leaks in Water Distribution Systems with Intermittent water
supply for Bengaluru a city of 8.5mil.(As part of EqWATER funded by Ministry of Human Resources Development, Govern-
ment of India). |
|
|
|
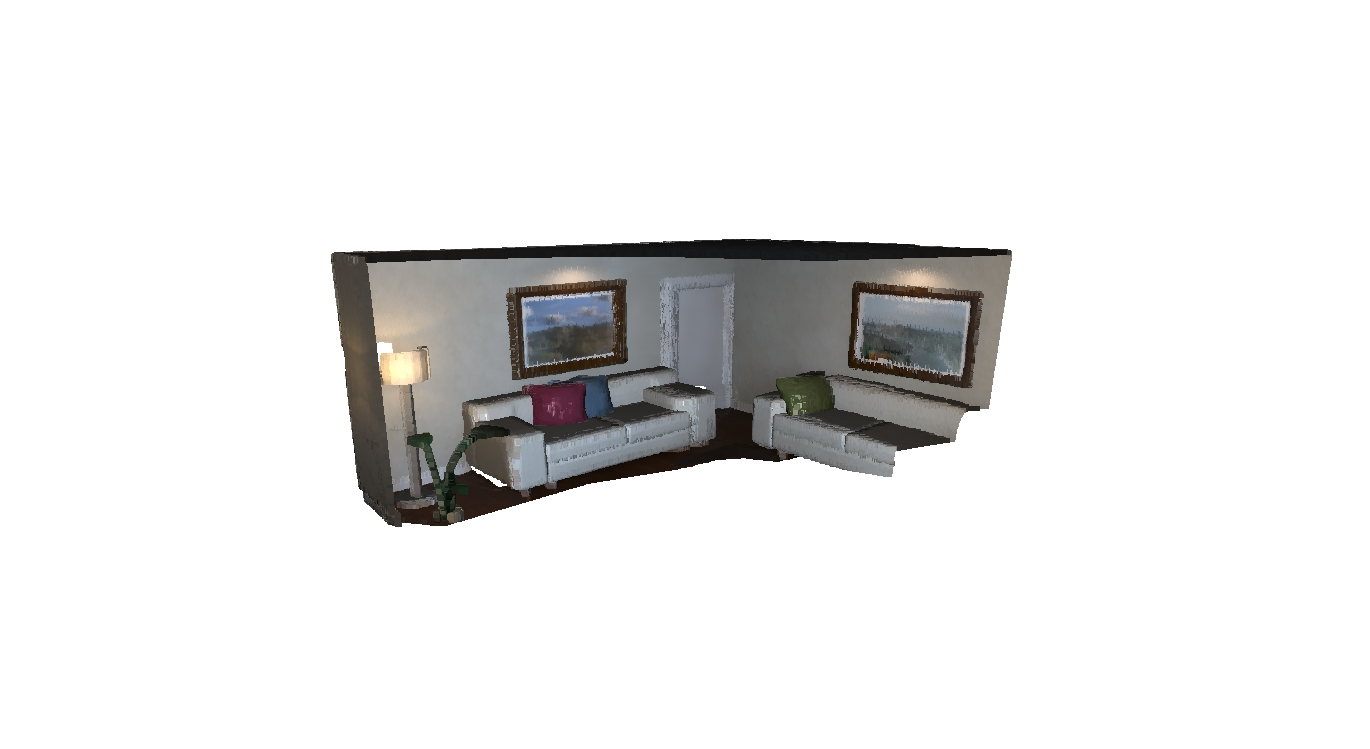
- Camera Localisation on the ICL-NUIM dataset using Iterative Closest Point Algorithm. |
|
Code
- Implemented a Differentiable Renderer for emission-absorption volumes. |
|
- Monte Carlo Localization(MCL) based robot localization for an indoor robot using laser rangefinder and odometry. |
|
Learning 3D representations using single views. |
|
Thank you to Jon Barron for the website template! |